
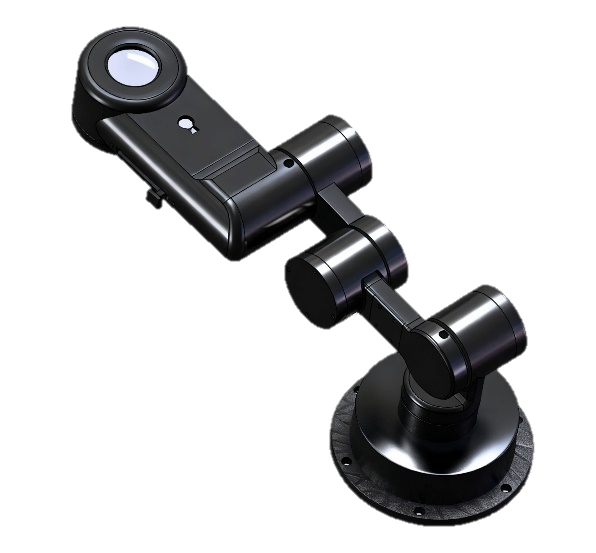
Adopting a homomorphic mapping design, the operator directly controls the
movement of the underwater manipulator via the shore-based master hand,
delivering an efficient operational experience of “what you see is what you control”.
The master hand communicates with the shore-based main controller through USB, and the master hand data as well as the manipulator angles are displayed in real time on the control software. It is equipped with an 18-bit output absolute encoder, and the damper parameters can be adjusted to suit different operational habits. The joint angle accuracy reaches 0.01°, featuring high-speed data transmission and low control latency.All motion control functions of the robot are integrated into the master hand. A single operator can control all functions of the dual-arm underwater robot with two master hands, improving single-person operational efficiency.